01The problem
Fire response is time-sensitive and dangerous. The prototype investigates whether an affordable mobile system can detect a visible flame, estimate its position, navigate toward it, and activate a suppression mechanism while retaining a clear record of its decisions.
02System design
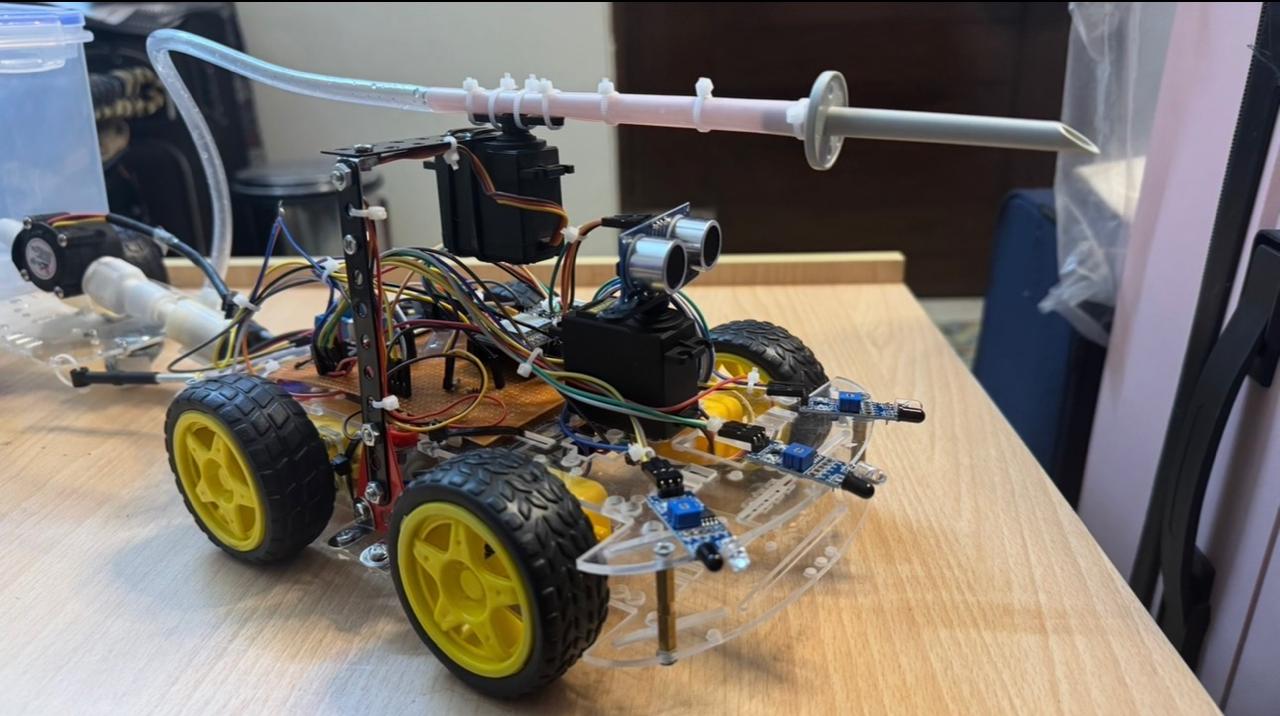
Video inference feeds a YOLOv8 fire detector. Detection results are passed to decision logic that works with ultrasonic and IR sensors, movement control, and an ESP32-based actuation layer. The modules remain separated so perception and hardware behavior can be tested independently.
03What I learned
The project made model performance only one part of a broader engineering problem. Sensor noise, mechanical constraints, communication reliability, and safe recovery behavior are equally important when a prediction has to produce a physical action.