01Context
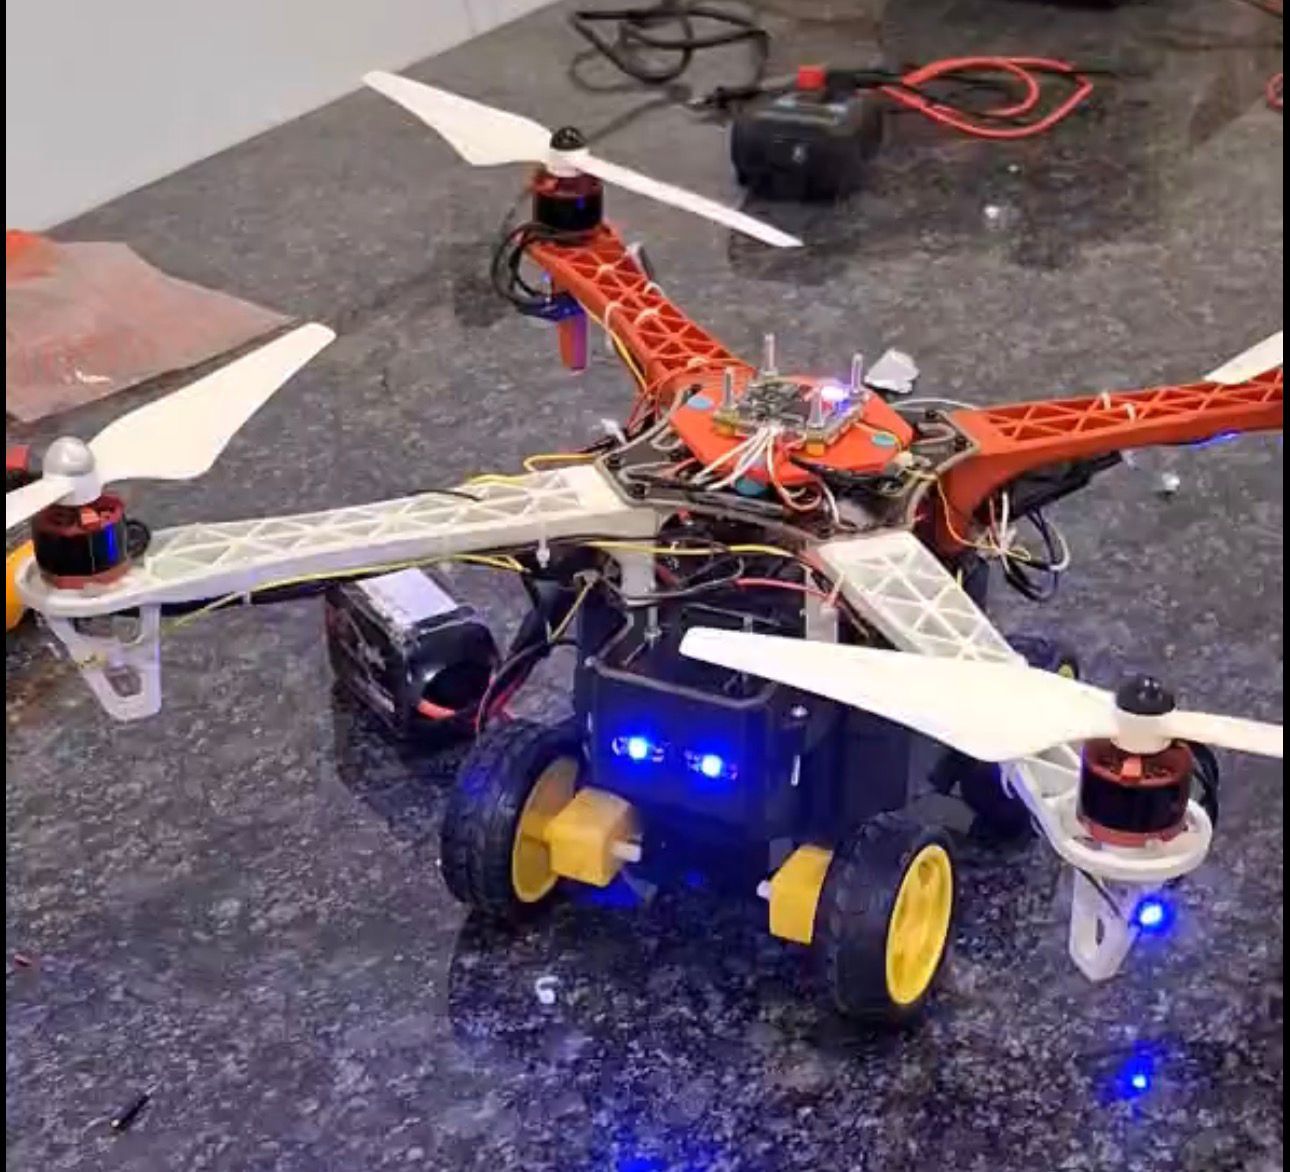
Conventional Drones have a very short flight time but are highly useful for crossing obstacles and getting proper surveillance footages. But drones do not fit in small places either. On the other hand, rovers are capable of covering different types of terrains and have a good battery backup. Combining the two systems and transforming between them gives a high range of usage time as well as it provides accessibility to different areas.
02Architecture
The flight controller F7 BotWing flies the drone and the ESP32 controls the rover. Both of them receive the same signal from the receiver in iBUS format and both decide it. As per the flags they decide which system needs to be activated and which one deactivated. Both work such that only one will be active at one moment. Both systems have their own power supply to prevent inter dependability.
03Current direction
A major feature of TEZA-TRON is its browser-based mission interface, through which operators can access telemetry, live camera feeds, system status, controls, and mission-related information from a Wi-Fi-enabled laptop or device. The camera stream can additionally be processed using computer-vision models, demonstrated through real-time person detection, providing a foundation for AI-assisted surveillance and search-and-rescue operations. The physical prototype has demonstrated ground navigation, traversal of slopes approaching 40°, aerial take-off from rover configuration, flight across ledges and terrain discontinuities, movement over staircases, transition between outdoor and indoor environments, first-person camera monitoring, and AI-based visual detection. These demonstrations validate the central concept of adaptive multi-terrain mobility. The platform has been custom developed through CAD modelling, iterative 3D design, FDM 3D printing, soldering, wiring, electronics integration, sensor mounting, and power-system design, enabling a low-cost, repairable, and modular construction approach. The principal USP of TEZA-TRON is therefore not simply the combination of a drone and rover, but the creation of a unified, modular and AI-ready robotic architecture capable of selecting the most appropriate mobility mode for the mission.