Research focus
The work investigates perception as one layer of a cyber-physical system. Reliable detection must eventually connect to temporal context, sensor agreement, uncertainty, and safe decision logic.
A computer-vision study exploring real-time object detection and multimodal perception for autonomous cyber-physical vehicle systems.
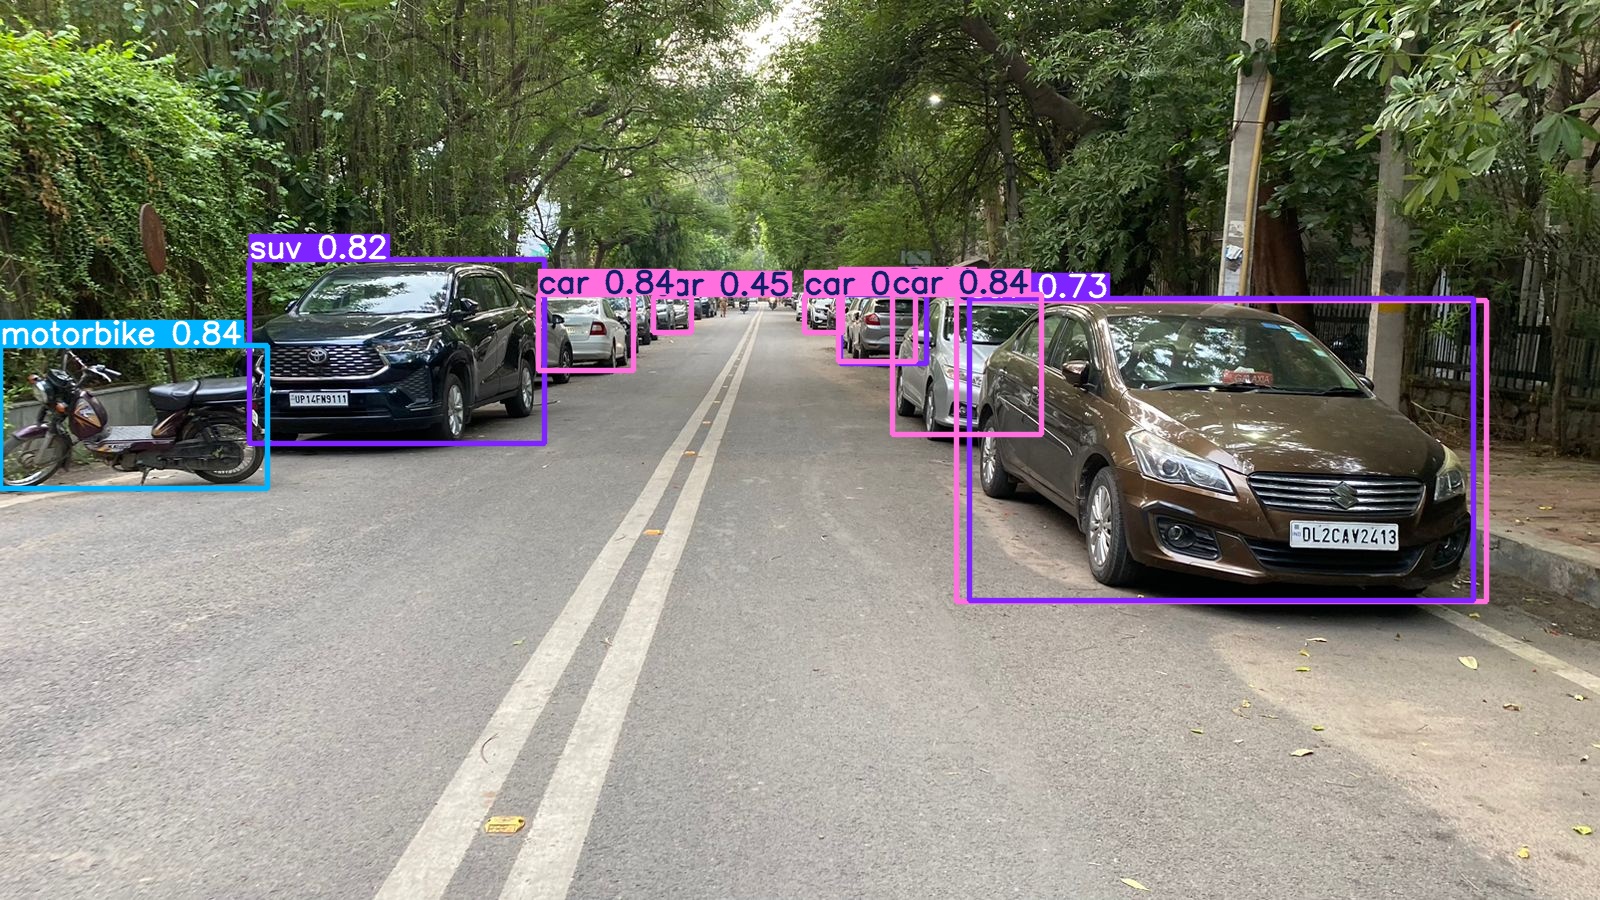
Object detection output for autonomous vehicle research
The work investigates perception as one layer of a cyber-physical system. Reliable detection must eventually connect to temporal context, sensor agreement, uncertainty, and safe decision logic.
YOLOv5 provides the object-detection base across still images, recorded video, and real-time input. The implementation creates a practical environment for comparing confidence, latency, and scene complexity.
Future development can extend the visual pipeline with tracking, depth and motion cues, sensor fusion, and explicit uncertainty handling before any control decision is made.